Gaussian mapping & scene graphs
LiDAR-enhanced 3D Gaussian reconstruction and structured scene representations, toward compact semantic maps for robot reasoning and interaction.
Lightweight embodied scene graphs →Embodied scene understanding & robotics
Associate Professor & Ph.D. Supervisor · Wuhan University
We focus on how robots build compact, meaningful world representations to guide navigation, planning, control, and interaction.
I am with the Electronic Information School at Wuhan University. My work spans robot 3D perception, SLAM, navigation, and intelligent unmanned systems. My current research agenda explores lightweight embodied scene graphs that connect vision-language models with 3D Gaussian Splatting, toward task-oriented robot world models.
Previously, I was a Postdoctoral Fellow in AirLab at the Robotics Institute, Carnegie Mellon University, working with Prof. Sebastian Scherer. I am currently visiting Prof. Lihua Xie's group at the School of Electrical and Electronic Engineering, Nanyang Technological University (NTU), Singapore.

Research directions
LiDAR-enhanced 3D Gaussian reconstruction and structured scene representations, toward compact semantic maps for robot reasoning and interaction.
Lightweight embodied scene graphs →Connecting cameras, LiDAR, and inertial sensing for calibration, localization, odometry, and geometric registration.
I2D-Loc, QuadricsReg & UniCalib →Geometric feature detection across camera models and challenging motion and illumination.
FE-LSD & ULSD →Current research agenda
How can a robot move from seeing geometry to understanding a scene and acting on instructions? We aim to connect the open-vocabulary semantics of vision-language models with efficient 3D Gaussian representations.
Explore incremental semantic–geometric mapping, with consistent open-vocabulary features and compact representations for resource-constrained robots.
Abstract Gaussian maps into objects, spatial relationships, and functional attributes that support semantic queries and task reasoning.
Investigate bidirectional updates between symbolic scene graphs and 3D geometry for instruction-driven navigation, interaction, and scene editing.
A closer look
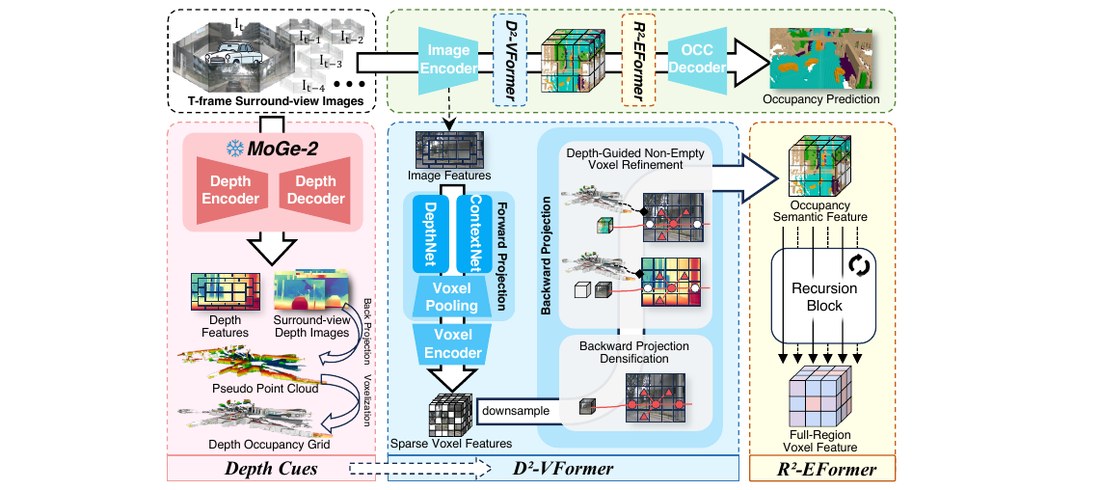
Semantic 3D perception · CVPR 2026
Depth and region guidance for semantic 3D occupancy prediction from surround-view cameras.
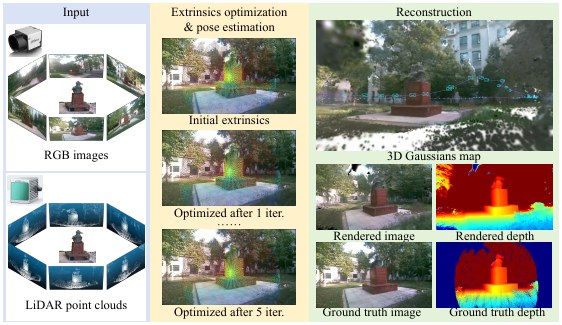
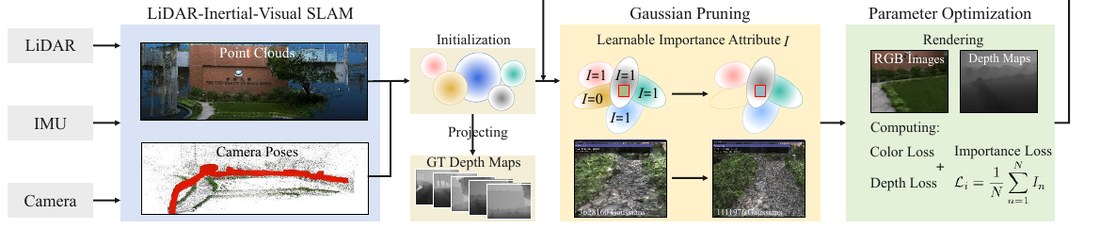
LiDAR-enhanced 3DGS · ICRA 2025
Integrating LiDAR and images for Gaussian splatting mapping with geometric and photometric supervision.
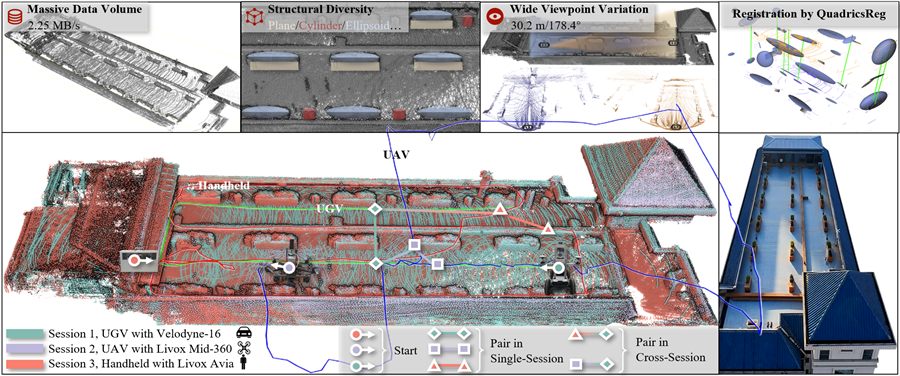
Structured 3D geometry · TRO 2026
Semantic quadric primitives for compact, large-scale point cloud registration.
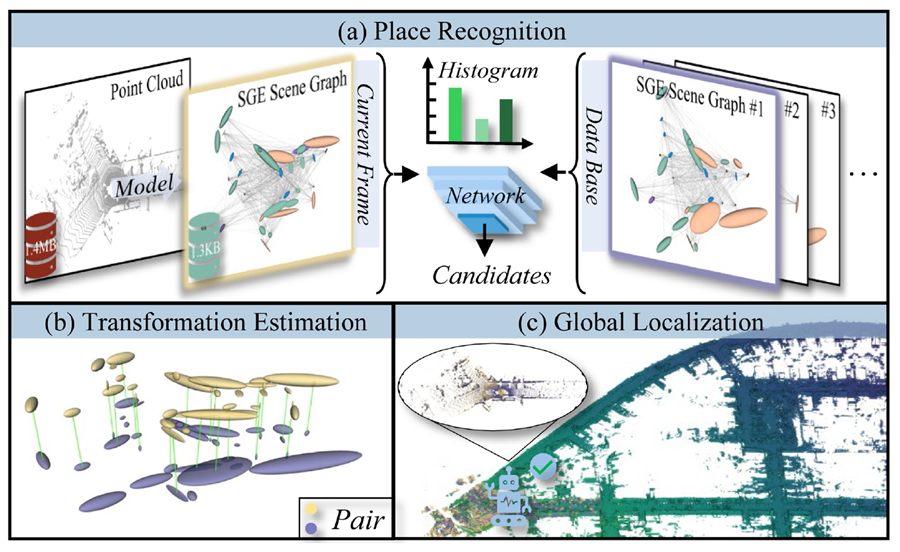
Gaussian scene graphs · RAL 2026
Semantic Gaussian ellipsoid scene graphs for efficient LiDAR global localization.
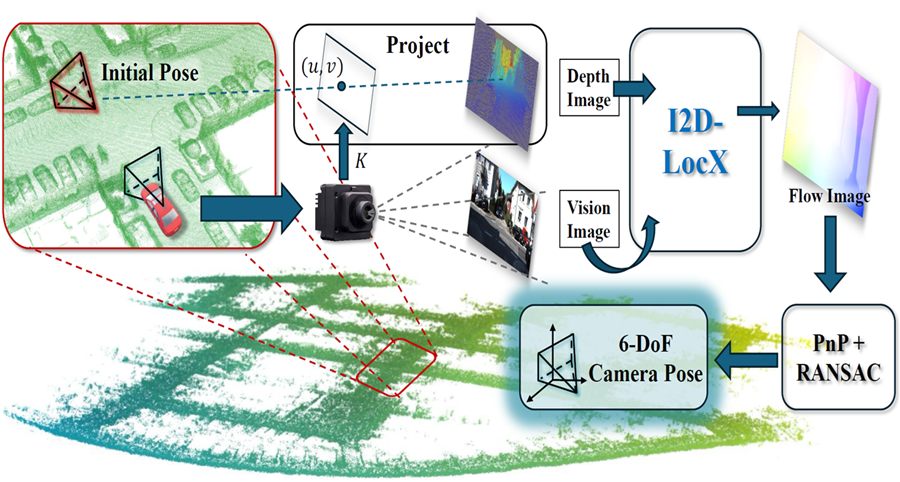
Cross-modal localization · RAL 2025
Precise and robust camera localization using prior LiDAR maps.
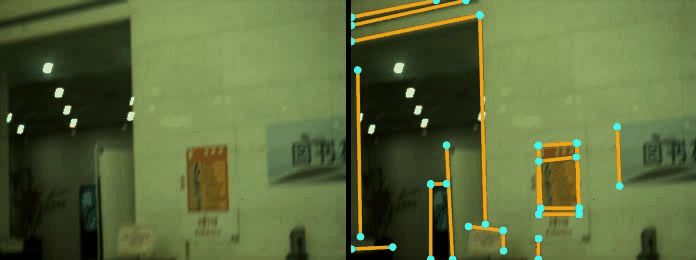
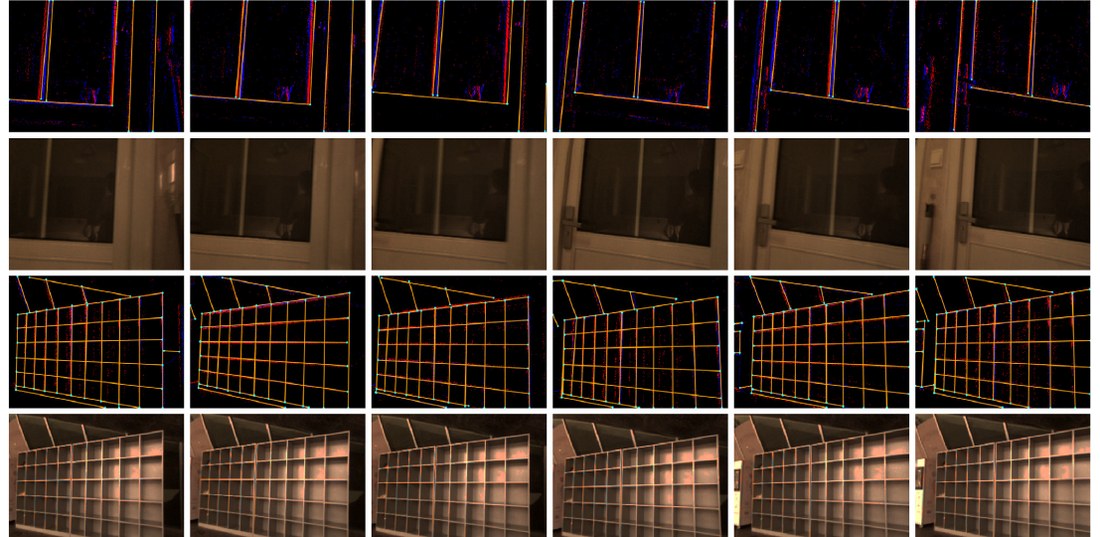
Event-based vision · TPAMI 2024
Combining events and images to detect line segments under motion blur.
Updates
Publications
Selected publications, ordered by year. Huai Yu is highlighted. * Corresponding author; # equal contribution.
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026.
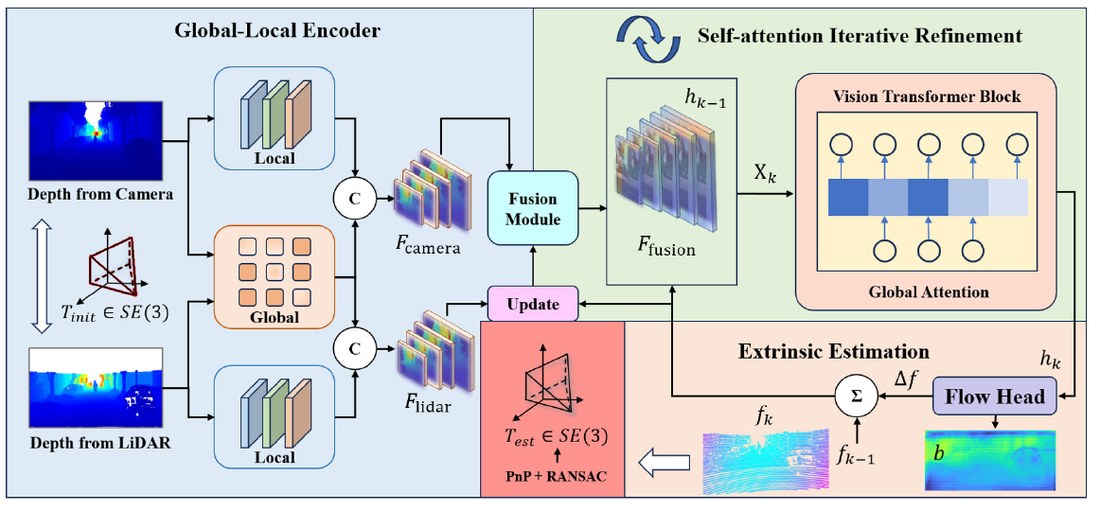
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026.
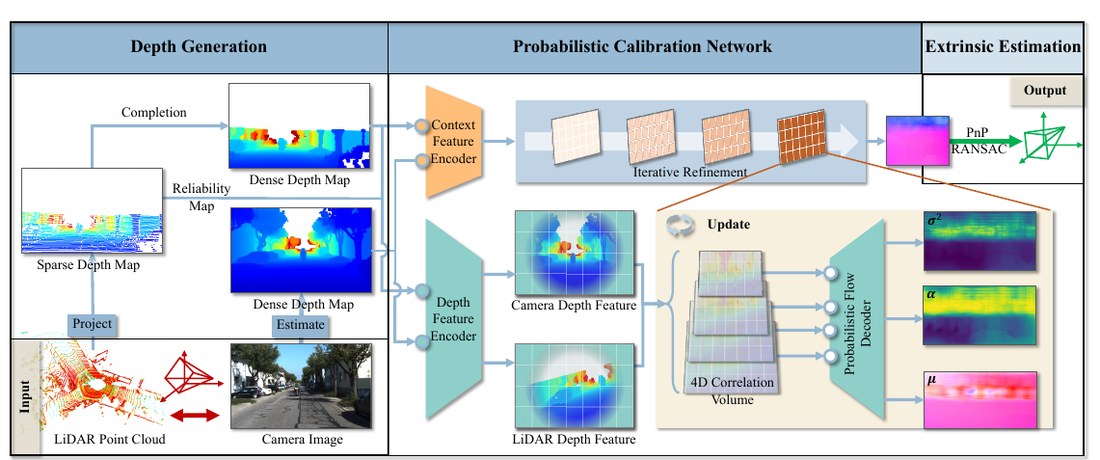
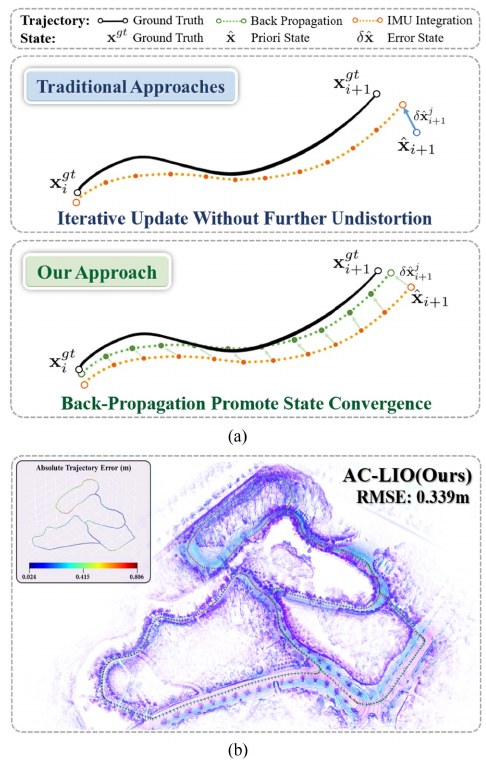
IEEE/ASME Transactions on Mechatronics, 2026.
IEEE Transactions on Robotics, 2026
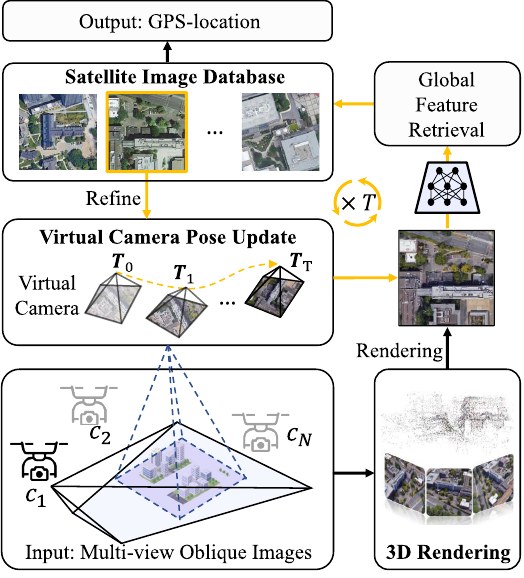
IEEE Transactions on Geoscience and Remote Sensing, 63, 2025.
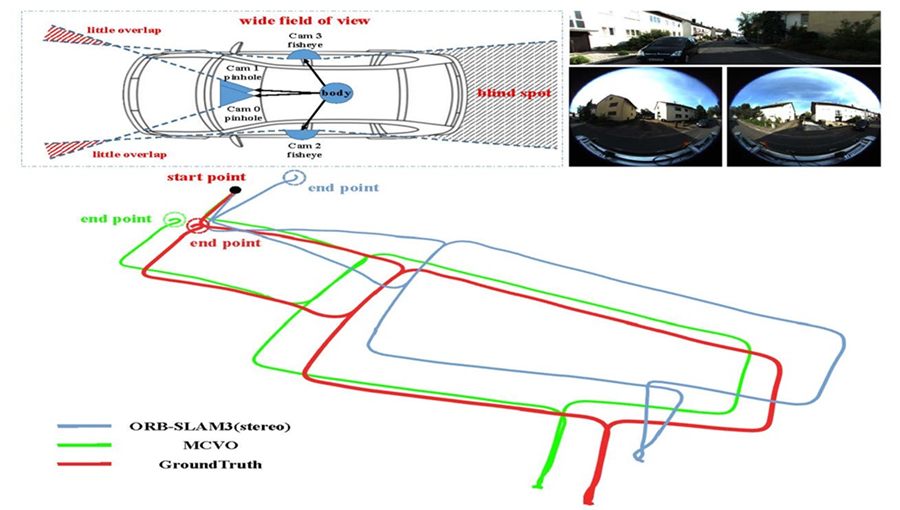
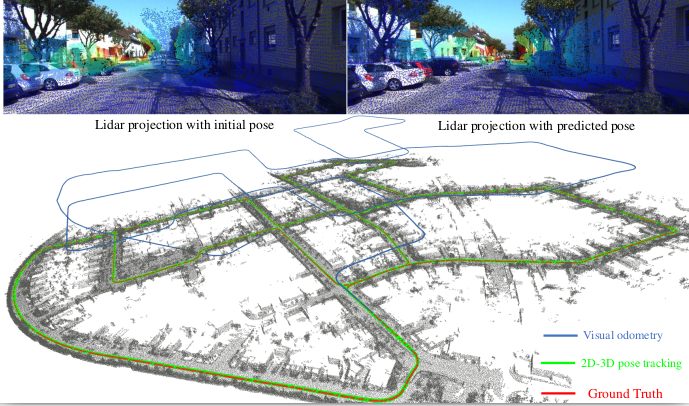
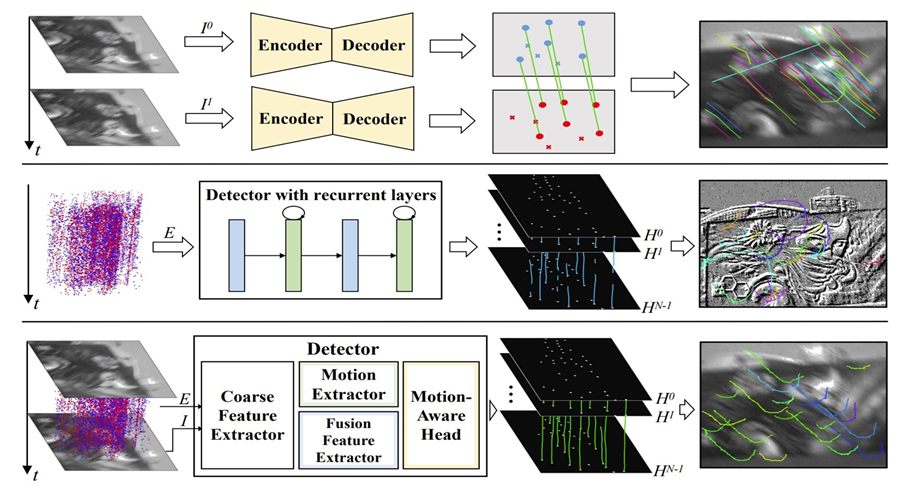
IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI), 2024
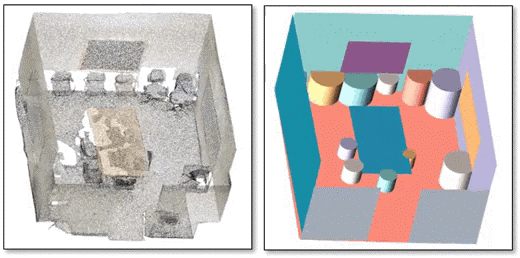
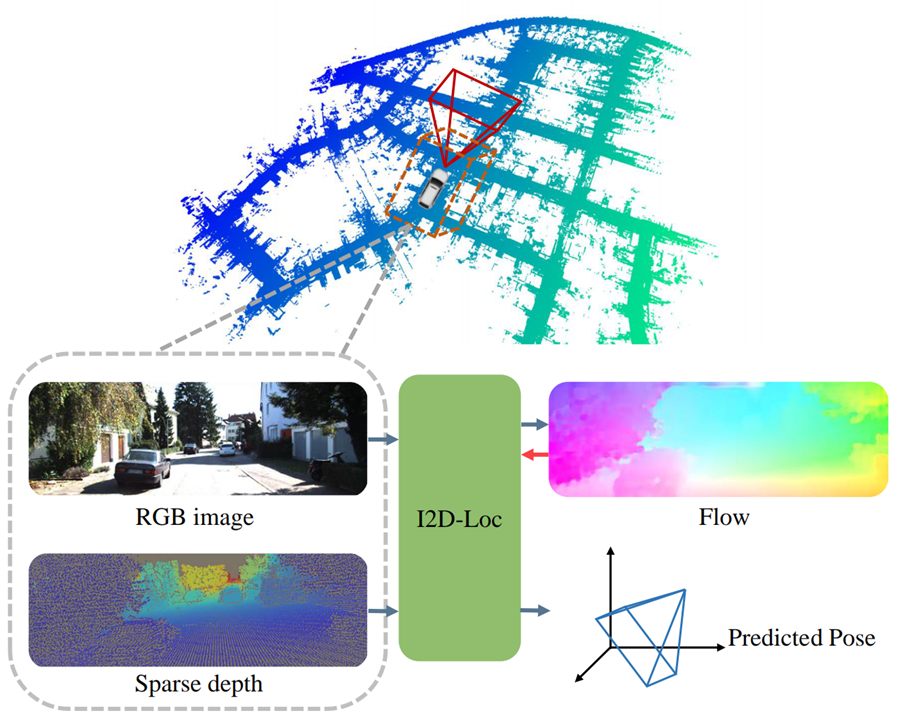
ISPRS Journal of Photogrammetry and Remote Sensing, 2022.
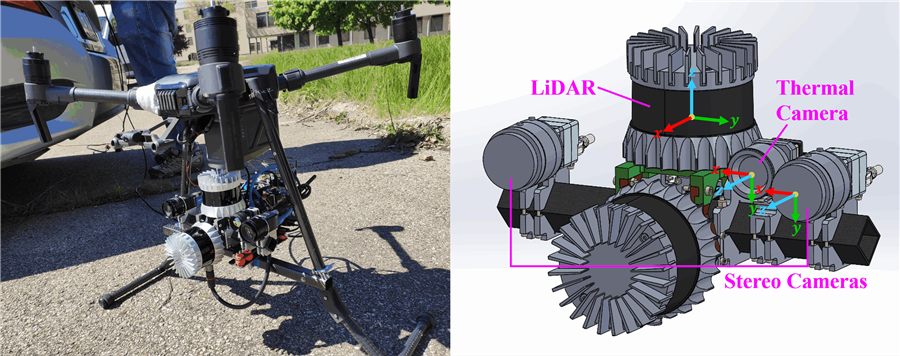
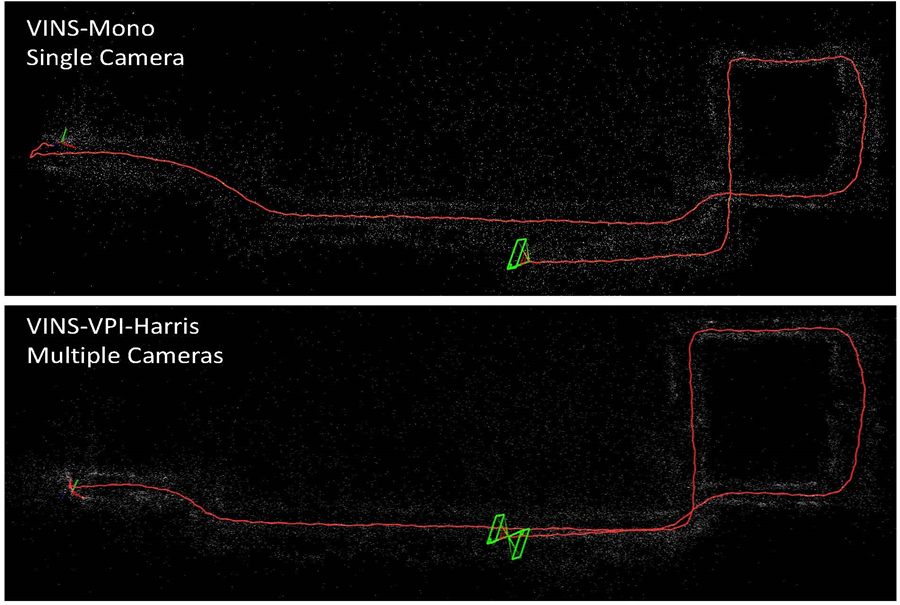
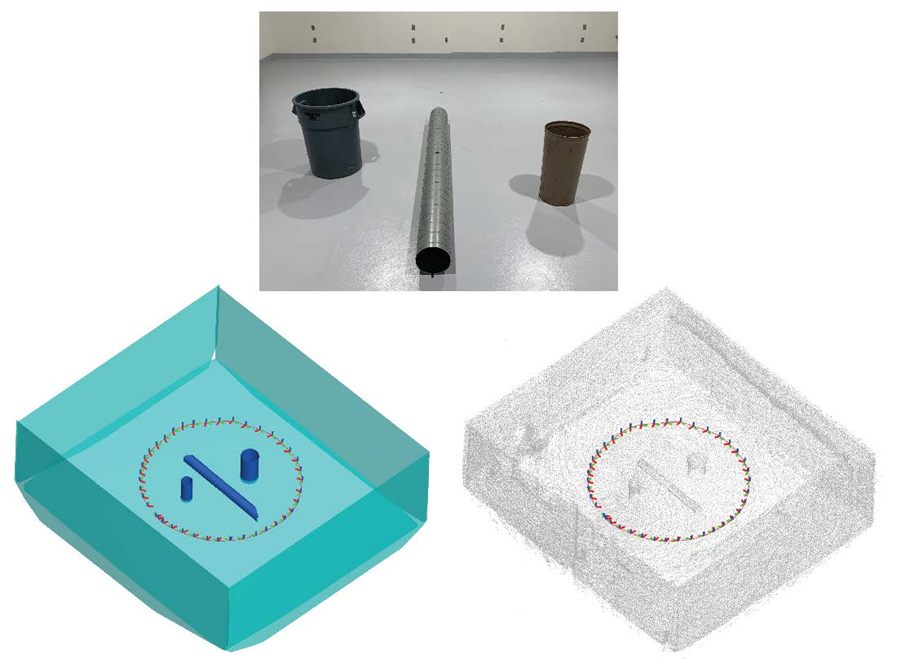
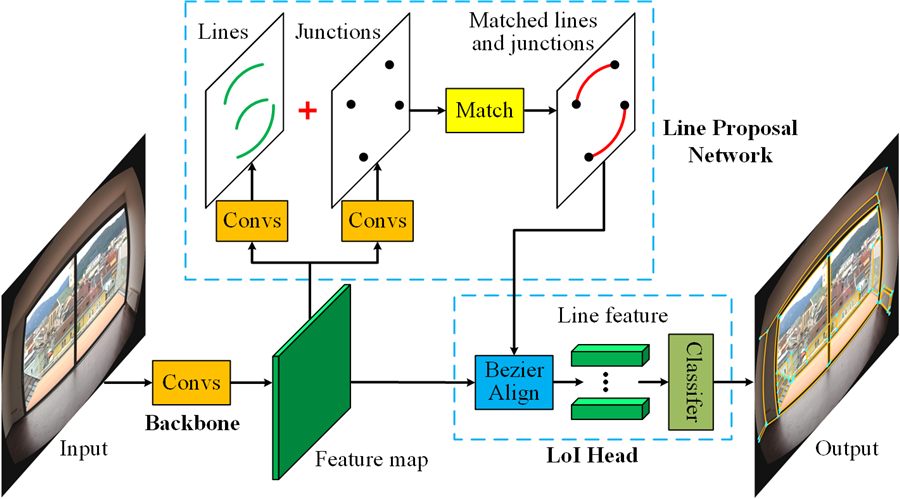
ISPRS Journal of Photogrammetry and Remote Sensing, 2021. The U. V. Helava Award – Best Paper 2021
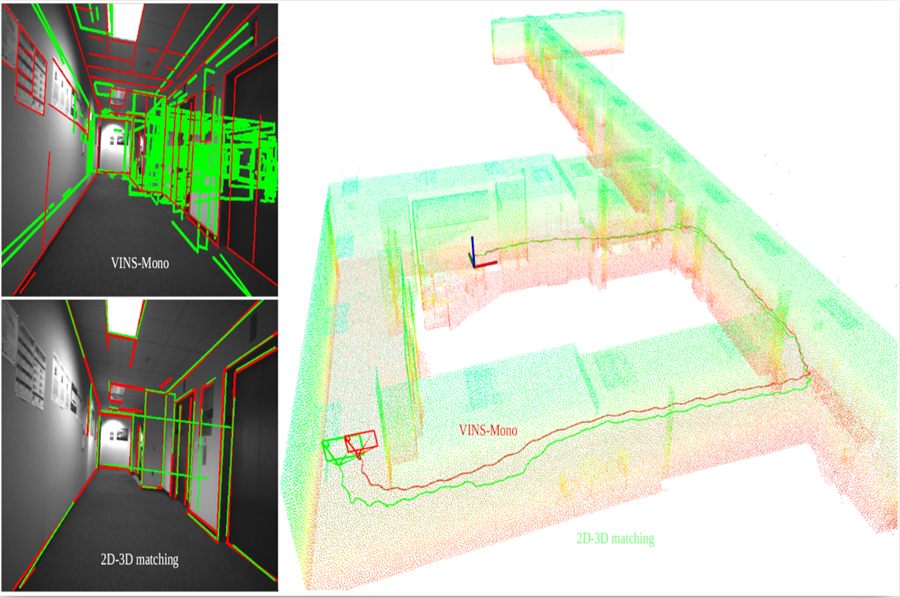
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2020.
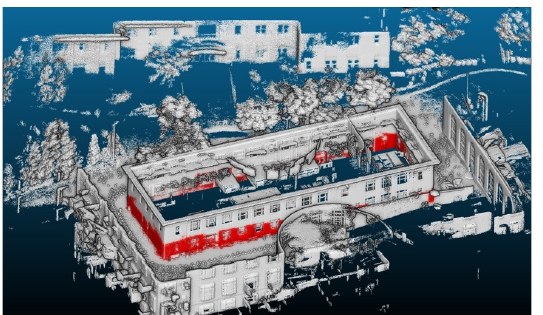
Background
Visiting Ph.D. in Robotics
Ph.D. in Communication and Information System
B.S. in Electronic Information Engineering
Nanyang Technological University
School of Electrical and Electronic Engineering
Wuhan University · Electronic Information School
Wuhan University · Electronic Information School
Carnegie Mellon University · Robotics Institute
Academic service
ISPRS U.V. Helava Award, Best paper of ISPRS J. P&RS, 2021
ULSD publication →
Join us & get in touch
I supervise Ph.D. and master's students in robotics and intelligent unmanned systems. Prospective students and postdoctoral researchers interested in 3D perception, Gaussian mapping, scene graphs, and SLAM are welcome to contact me.
Graduate recruitment information (中文) ↗Electronic Information School · Wuhan University
Yugang-Songxiao Building
Wuhan, Hubei, China